A greige studio floor with small islands: a two-arm robot folding a shirt, a robot dog by pine trees, a robot arm picking tomatoes, and a person at a desk
Kenji Phang

I teach cheap robot arms to do expensive work.

Robotics and AI engineer. I run a self-funded lab in London and Kuala Lumpur where USD 1k arms learn the jobs of USD 20k ones, and I build the agents that run companies. Before that, founding AI engineer at Goldman Sachs and Fern Labs (acq. by Poolside).

01 · Robots

Real to sim to real.

One pipeline: record a real task, rebuild the place in simulation, train pi0.5, SmolVLA and ACT policies there, then take them back to the arm. Six rooms so far. Every clip below is from my own runs, with what worked and what didn't.

Real robot · head camera and both wrist cameras
Teleoperated folding demo · 2× speed

Home lab · Sep 2026 –

A USD 1k robot that folds clothes

An XLeRobot: two SO-101 arms on a wheeled base with three cameras. I took it from loose servos to leader–follower teleop, built a dual-arm demo recorder, and wrote my own cloth-folding training stack.

35 real demosLOI from an industrial partner in KL

No autonomous real fold yet. The first policy trained for 1,000 steps; the next run trains longer on the cleanest demos.
Sleeve-under fold in Isaac Sim · experiment 242
LeHome baseline reproduced · folded in 329 steps

Cloth folding · Isaac Sim

242 experiments on one fold

I reproduced the LeHome Challenge folding policy on rented GPUs, then went after a harder fold: lift a side so gravity lays the sleeve underneath.

  • A mesh check caught a fake success: the "fold" was really the whole shirt flipping over.
  • After that, every result had to pass checks on the cloth itself plus a video review.
pi0.5 picking inside a room rebuilt from a 60-second phone video
Robot-height view · before and after gap filling
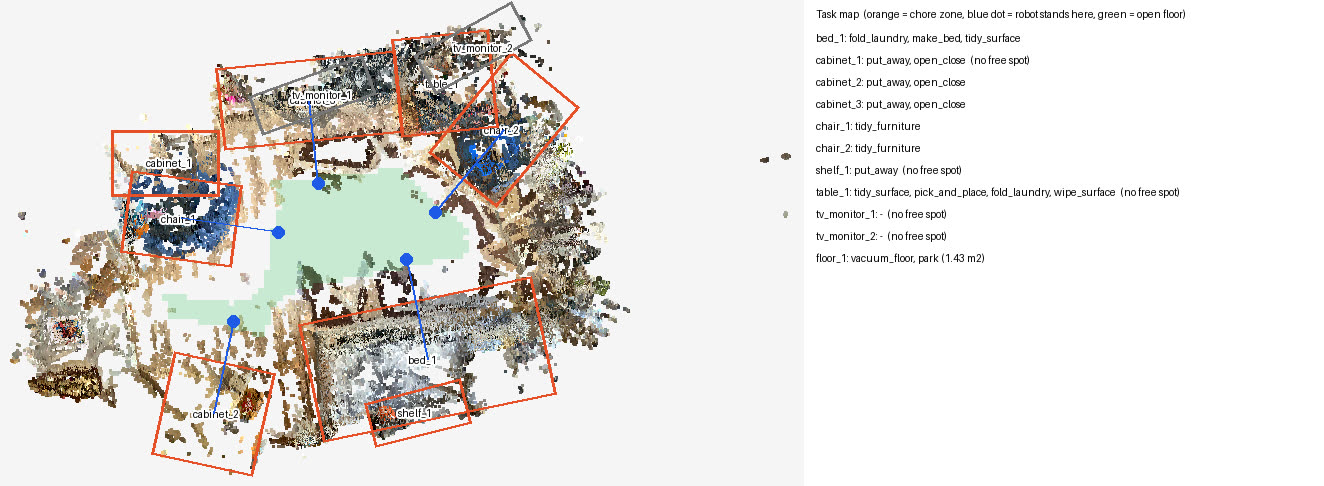
Top-down chore map of the room with zones, stand spots and open floor
Chore map from video alone

Home Twin · Oct 2026

A phone video becomes a room a robot can work in

Film a room, rebuild it as a 3D map and a Gaussian splat, drop it into Isaac Sim, and let a pretrained pi0.5 policy act in it. Then ask for a chore in chat: Claude picks the spot, starts the GPU and sends back the video.

3/5 in the phone room vs 2/5 stock8/9 furniture found, no labels
Claude as the robot's brain · path-traced in Isaac
Claude plans, a camera-only policy cleans
Same toilet after 0 to 6,666 practice runs

Restroom cleaning · MuJoCo, Isaac, DimOS

Splitting what to do from how to do it

Claude looks at the cameras and names the next step; a SmolVLA trained on the teacher's step labels does the scrubbing. I also ran PPO practice and DAgger, and wired the same skills into DimOS over MCP.

bowl cleaning 24% → 31% with step conditioning
Greenhouse harvest · fruit only comes off past a 4 N pull
ACT pick from cameras only · 2× speed

Farm · MuJoCo

A greenhouse that grows for 13 weeks

Tomato vines grow, ripen and get lowered on a real crop schedule, and the robot harvests twice a week. I recorded harvest demos and trained SmolVLA and ACT to pick from cameras alone.

336 demos, 151k frames across the sims
Scout drone maps, the Go2 samples · rendered in Blender
Photoreal replay of the simulated gait

Forest · DimOS

A robot dog that surveys a forest

A procedural forest in DimOS where a simulated Unitree Go2 walks to soil-sample sites. One MCP call starts the survey; an agent runs the rest.

4/4 sites on both test forestslidar 0.26× → 1.7× real time

Steep slopes still break navigation; that needs rough-terrain training of my own.

02 · Agents

The agents that do the building.

Most of the robot work above was run by coding agents on a harness I built. I film the process and post it.

Farplane

A local-first harness for long-running Claude Code and Codex work: 49 skills with evals, tickets, independent review and QA gates, scheduled automations. 830+ commits since March.

Company brain

An agentic operating system for two Malaysian companies: it reads WhatsApp and meeting notes, keeps daily working memory and writes the weekly review back to the team's task board.

Build logs on Instagram: 23 Sep reel · 28 Sep reel

03 · Work

Where I've worked.

2026 – now

Zanarkand TechnologiesFounder, self-funded lab

Robot learning on low-cost arms and agentic systems for companies. Selected engagements: 60x (AI for private equity), Prosus (AI personal assistant), Isara Labs (deep-research agents).

2025

Fern LabsFounding AI engineer · acq. by Poolside

Coding-harness evals and a Kubernetes sandbox system on SWE-Bench; autonomous app-development workflows on an in-house agent runtime.

2024 – 2025

Goldman SachsFounding AI engineer of division

First hire on a back-office AI team. Financial-statement review automation (about USD 5M ROI), bank-statement matching from 65% to 90%, 12 firmwide AI trainings.

2022 – 2023

Interact SoftwareFull-stack software engineer

Moved deployment tooling to AWS, cutting storage cost 50%.

2020 – 2024

University of ManchesterBSc Computer Science, First Class (84%)

Dissertation on human motion generation with diffusion models.

04 · Feed

Everything I've built, newest first.

Robot runs, build logs, hackathon wins and side projects. Keep scrolling and older posts load in.